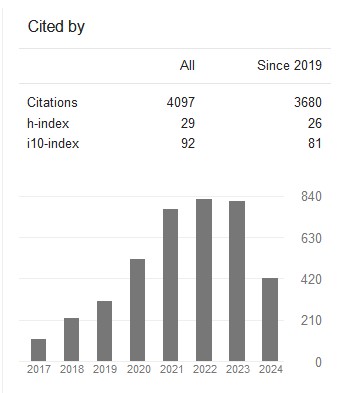
Google Scholar Analysis
For Authors

ijaems Issue
Type-1 Fuzzy-PID Depth Control-Based Simulation and Analysis of Underwater Vehicles( Vol-12,Issue-3,May - June 2026 ) |
|
Author(s): Chih-Ching Hung |
Download Full Text PDF
Total View : 76
Downloads : 2
Page No: 452-459
|
Keywords: |
|
|
underwater vehicle, depth control, type 1 fuzzy PID, ocean wave disturbance, sensor time delay |
|
Abstract: |
|
|
To address the limitation of conventional PID controllers in underwater vehicle depth control, where fixed gains cannot balance rapid response and overshoot suppression, this work takes the depth channel of an underwater vehicle as the research subject. A mathematical model for vertical motion is established, and the corresponding depth control transfer function is derived. A type 1 fuzzy PID controller with online parameter self tuning is developed. The controller uses depth error and its rate of change as inputs, and adjusts proportional, integral and derivative gains in real time via fuzzy inference. Simulation models are constructed in the MATLAB/Simulink environment. Control performances of the conventional PID and the type 1 fuzzy PID are compared, sinusoidal continuous depth variation, ocean wave disturbance and sensor time delay. Simulation results reveal that the type 1 fuzzy PID converges faster after disturbance removal for step inputs, and its settling time under sensor time delay is less than half that of the conventional PID. The proposed type 1 fuzzy PID effectively suppresses overshoot while maintaining favourable response speed, and exhibits better adaptability and robustness against wave disturbances and sensor time delay. |
|
| Article Info: | |
|
Received: 26 Feb 2026; Received in revised form: 19 Mar 2026; Accepted: 23 Apr 2026; Available online: 28 May 2026 |
|
Cite This Article: |
|
|
Citations:
APA | ACM | Chicago | Harvard | IEEE | MLA | Vancouver | Bibtex
| |
Share: |
|
 DOI: